Process controlSubscription
PID tuning: from the step test to the values in your controller
Find the process gain, dead time and time constant with a step test, calculate P, PI or PID tuning by IMC/Lambda or Ziegler-Nichols and see the values in your device’s convention: ideal, series or parallel form, gain or proportional band, integral in time or repeats. The simulation shows how the loop responds before touching the real process.
Subscription tool
Read the explanation and the example freely. To use the tool with your own data, log in to an account with active access or subscribe.
Read the explanation and the example freely. To use the tool with your own data, log in to an account with active access.
Want to check the quality first? Free, no sign-up: 4–20 mA calculator · residential cable sizing (whole house)
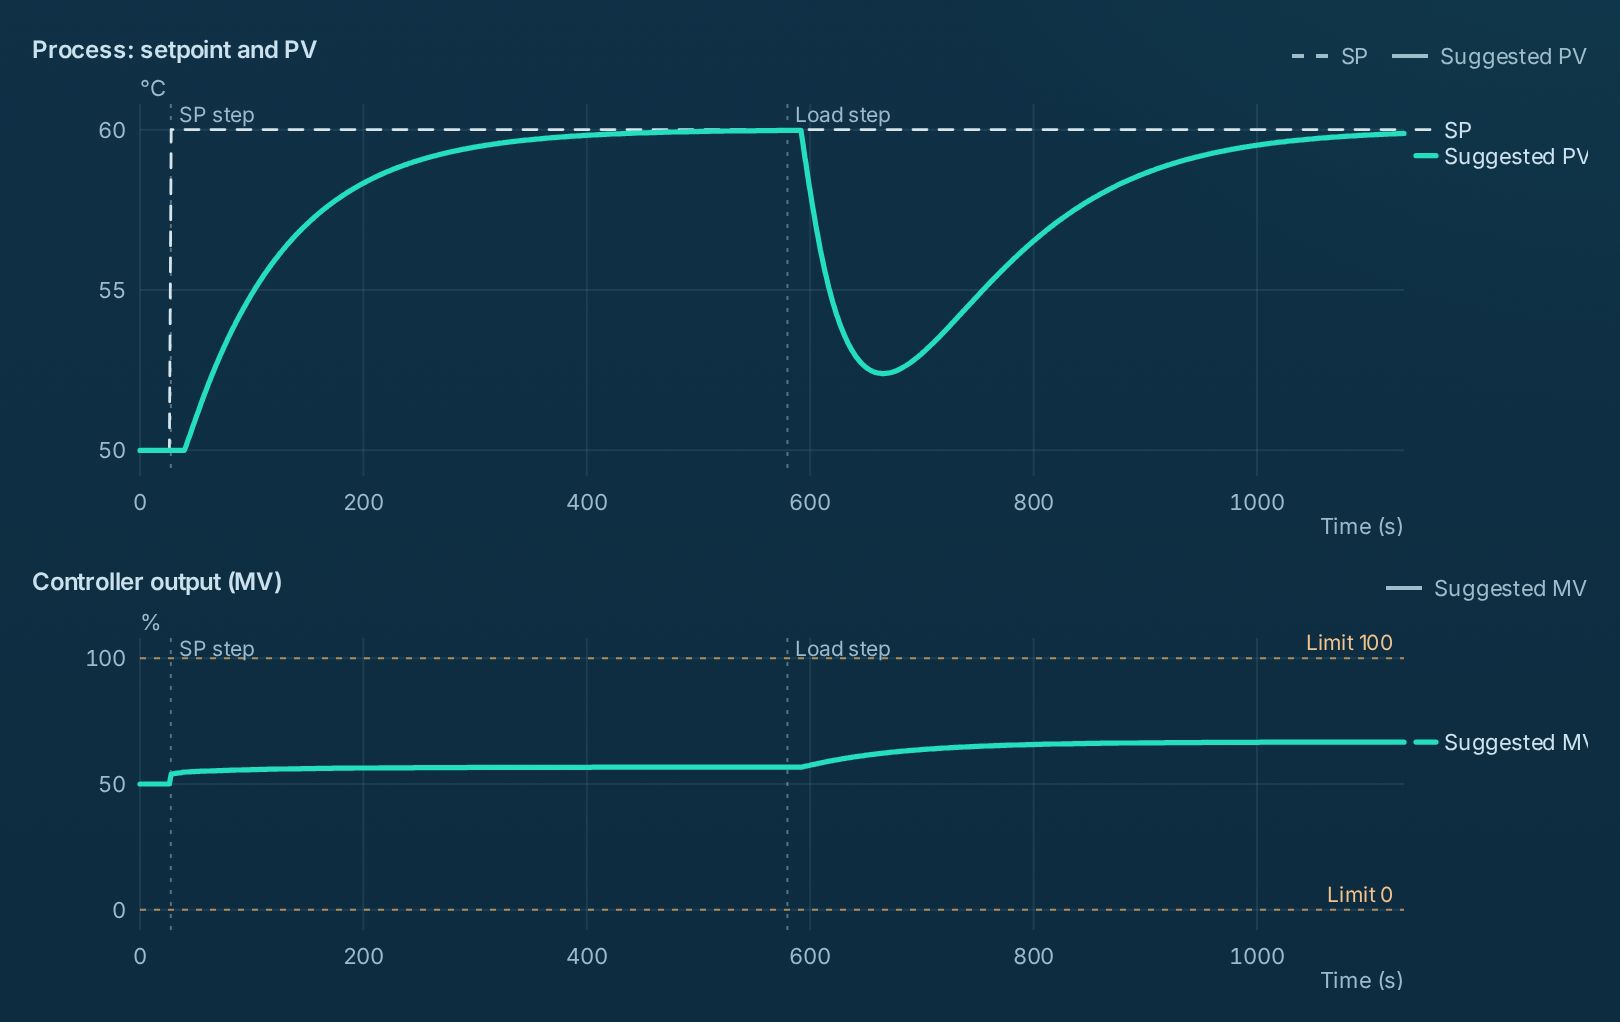 Enlarge
Where it helps at work
- Tune a new temperature, pressure, flow or level loop with a justified starting point.
- Understand why a loop oscillates or is slow, by looking at the dead time and time constant.
- Take the same tuning to a PLC or controller that uses proportional band or repeats per minute.
- Compare the device’s current tuning with the suggested one, in the same simulation.
What you enter
What you get
Worked example: electric furnace: from the step test to the proportional band
The temperature of an electric furnace is controlled by a PID (PV range 0 to 150 °C, output 0 to 100 %). With the loop in manual and the furnace steady, the output went from 40 to 50 % and the temperature rose from 80 to 95 °C. It covered 28.3 % of the change (84.2 °C) at 32 s and 63.2 % (89.5 °C) at 72 s. The controller uses the ideal form, with proportional band and integral in minutes. Which values should be programmed for a PI?
| MV before → after the step | 40 → 50 % |
|---|---|
| PV before → final | 80 → 95 °C |
| Time to 28.3 % | 32 s |
| Time to 63.2 % | 72 s |
| PV range | 0 … 150 °C |
| Method and controller | IMC / Lambda · PI · conservative |
| Device convention | Ideal · PB % · Ti in min |
| Identified process | K 1.5 °C/% · θ 12 s · τ 60 s |
|---|---|
| Suggested PI tuning | Kc 0.3922 %/°C · Ti 60 s |
| On the controller (ideal, PB) | PB 170 % · Ti 1 min |
| With balanced response | PB 120 % |
How to read it
The test describes the process with three numbers: a gain of 1.5 °C per % of output, a dead time of 12 s and a time constant of 60 s. With θ/τ = 0.2, the dead time is small compared with the time constant and the loop is easy to control. With the conservative response of the IMC/Lambda method (λ = 90 s), the PI gets Kc = 0.3922 %/°C and Ti = 60 s. In a controller with proportional band that becomes PB = 170 % and Ti = 1 min: the band depends on the PV range (150 °C), which is why the same tuning has different numbers in each convention. If a faster response is needed, the balanced profile (λ = 60 s) leads to PB = 120 %. The values are the starting point: validate them on the real loop, with authorization.
Limits and cautions
- The methods start from a first-order plus dead time model; integrating processes (level without free outflow) or inverse response need care and another model.
- The tuning is a simulated starting point, not a validated configuration: test on the real loop, with authorization and procedure.
- The tool does not assume any manufacturer’s convention: confirm form, units and action in the PID block manual.
- It does not connect to the PLC or controller; you type the values.
Technical basis
First-order plus dead time model from the step test, IMC/Lambda or Ziegler-Nichols tuning and conversion to ideal, series and parallel forms.
- Seborg, Edgar, Mellichamp and Doyle — Process Dynamics and Control (two-point method and IMC)
- Åström, K. J.; Hägglund, T. — Advanced PID Control (ideal, series and parallel forms)
- Ziegler, J. G.; Nichols, N. B. (1942) — Optimum settings for automatic controllers
In the full version, you can
- Identify the process with the step test and calculate P, PI or PID by IMC/Lambda or Ziegler-Nichols.
- Convert to your device’s convention: form, gain or band, integral and derivative.
- Simulate the loop live, with disturbance, and compare with the current tuning.
- Export an unbranded PDF report and keep the work on your device or in your account, to open it on another device.
ALOGY Tools subscription
One plan unlocks every subscription tool, with PDF reports and work kept in your account, to open on your phone and computer.
- Every subscription tool, in Portuguese, English and Spanish
- Pix or card on Asaas’s secure page, no boleto
- 7 days to withdraw with a full refund; after that, cancel renewal whenever you want
Frequently asked questions
Why does the same PID have different numbers in each controller?
Because manufacturers use different conventions: gain in engineering units or %/%, proportional band, integral in seconds, minutes or repeats per minute, and ideal, series or parallel forms. The tuning is the same; only the way of writing it changes.
What is dead time and why does it matter so much?
It is the time between moving the output and the PV starting to react. The larger it is compared with the time constant, the harder it is to control without oscillation: that is why the tool warns when θ/τ is high.
Can I use it without a step test?
Yes, if you already have K, θ and τ from another source. Simple mode also includes study processes to understand the effect of each parameter.